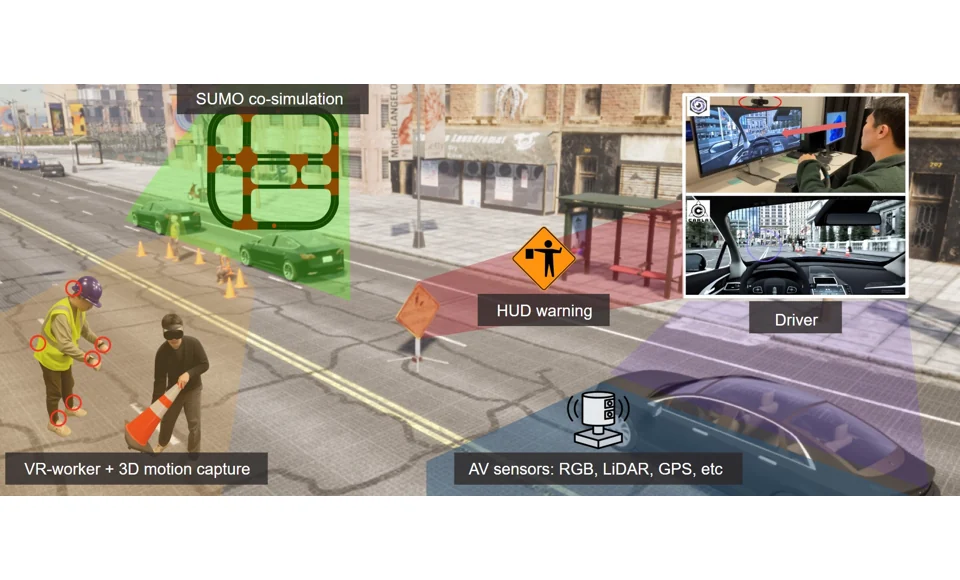
A dual-participant simulation platform for studying driver–worker interaction in safety-critical road scenarios, with human motion, gaze, vehicle sensing, and CARLA–SUMO co-simulation.
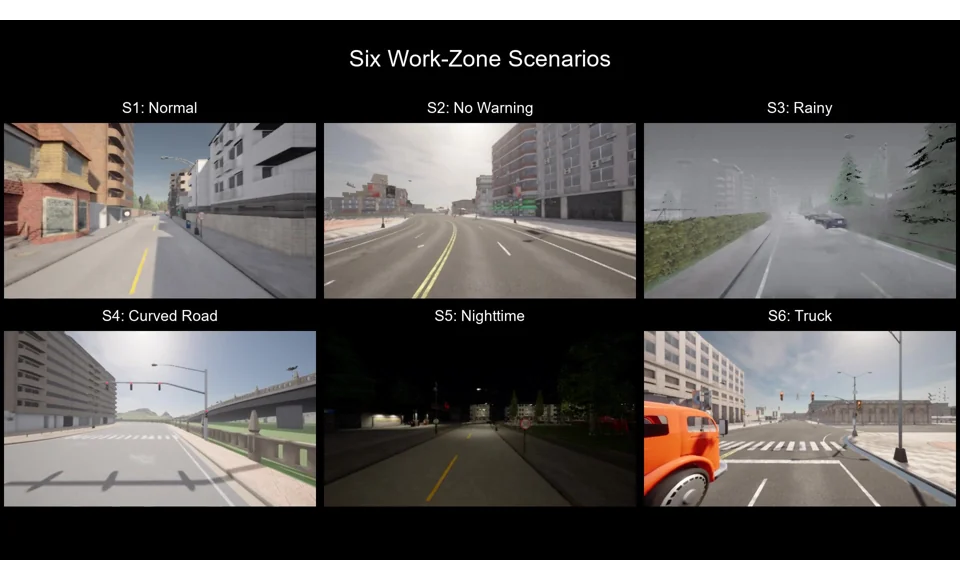
Human-in-the-loop driving data and trajectory prediction in work zones. The dataset captures 1,183 trajectories from 33 drivers across six scenario conditions and three work-zone configurations.
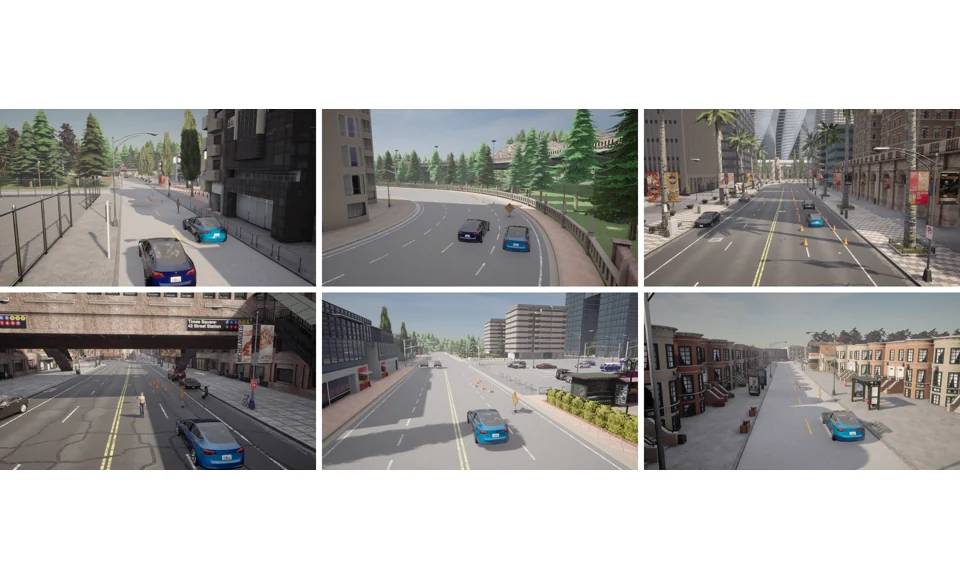
A configurable CARLA–SUMO testbed with six scenario families for training and evaluating a PPO motion planner with a structured spatial-temporal scene encoder.