New York University
PhD, Transportation System
Sep 2023 – May 2027 (expected)
Human interaction · Simulation · Intelligent driving
PhD Candidate · New York University
Expected graduation · May 2027
I build human-in-the-loop driving simulations to study how people interact with vehicles and each other in complex road environments.
My work spans research and system development: building VR interfaces and simulation tools, connecting multimodal data streams, and studying behavior, trajectory prediction, and autonomous driving policies.
Interested in research and engineering opportunities in HCI, autonomous driving, robotics, and applied machine learning.
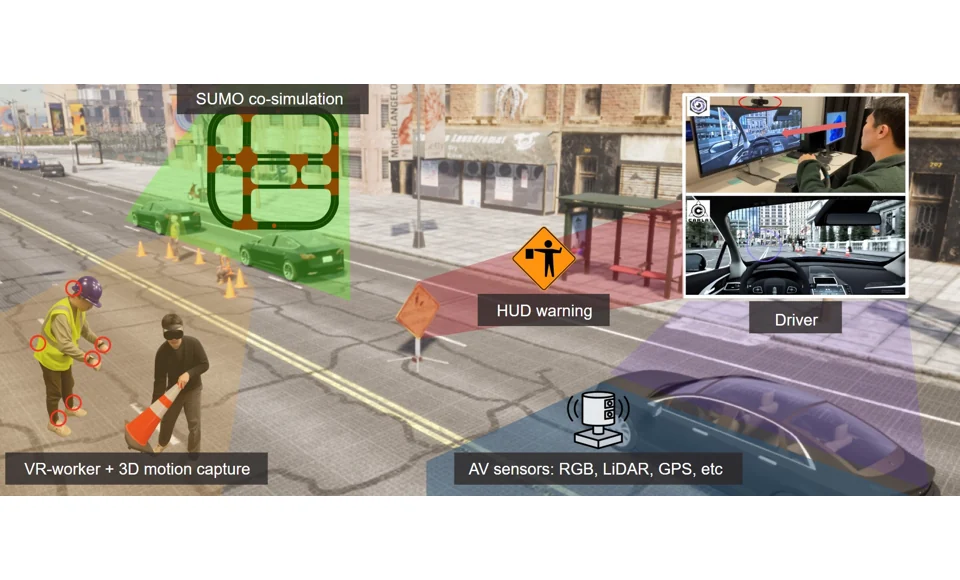
A dual-participant simulation platform for studying driver–worker interaction in safety-critical road scenarios, with human motion, gaze, vehicle sensing, and CARLA–SUMO co-simulation.
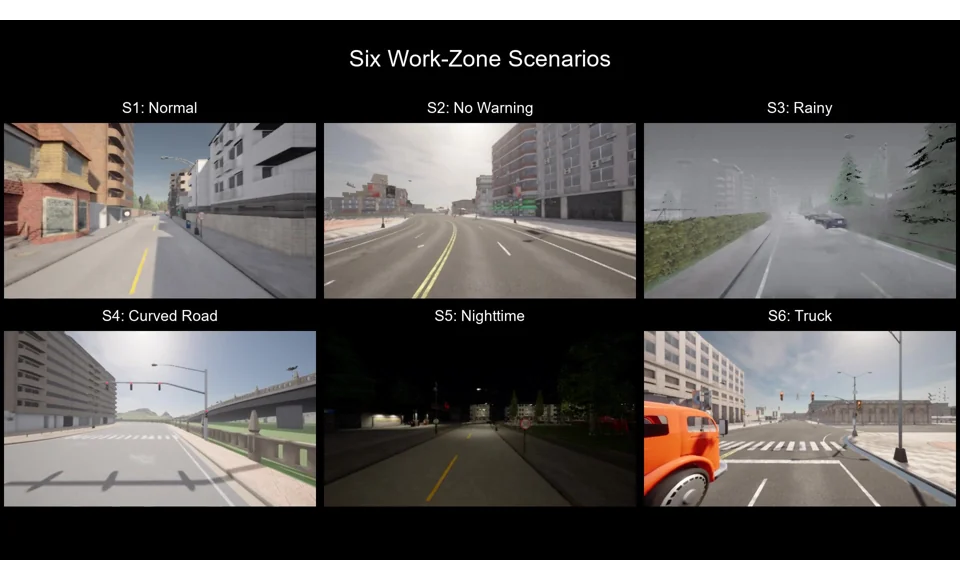
Human-in-the-loop driving data and trajectory prediction in work zones. The dataset captures 1,183 trajectories from 33 drivers across six scenario conditions and three work-zone configurations.
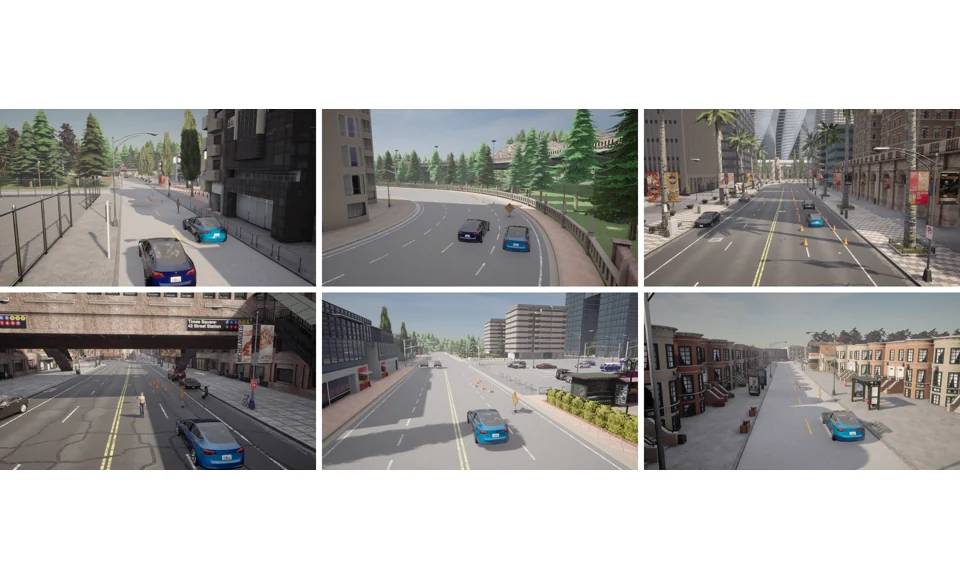
A configurable CARLA–SUMO testbed with six scenario families for training and evaluating a PPO motion planner with a structured spatial-temporal scene encoder.
ACM AutomotiveUI · Conference paper
Journal of Transportation Safety & Security · Journal article
ICRA Future of Construction Workshop · Workshop paper
IEEE/CVF CVPR · Highlight paper
PhD, Transportation System
Sep 2023 – May 2027 (expected)
MS, Transportation Engineering
Sep 2021 – Mar 2023
BE, Civil Engineering
Sep 2016 – Jun 2020
LiDAR Intern · San Jose, CA
Jun – Sep 2022
Built real-time LiDAR diagnostics and automated hardware validation.